Quang Huy Dao
Robotics Engineer, VinMotion Inc.

Robotics Engineer
VinMotion Inc., US
I joined VinMotion in April 2025 as a Robotics Engineer, working on whole-body motion for humanoid robots that walk, dance, recover from falls, and hold up in front of a crowd. Since October 2026 I have been a Robotics Engineer at VinMotion Inc. (US). The photo is from Vingroup’s 33rd anniversary, with MiniMotion.
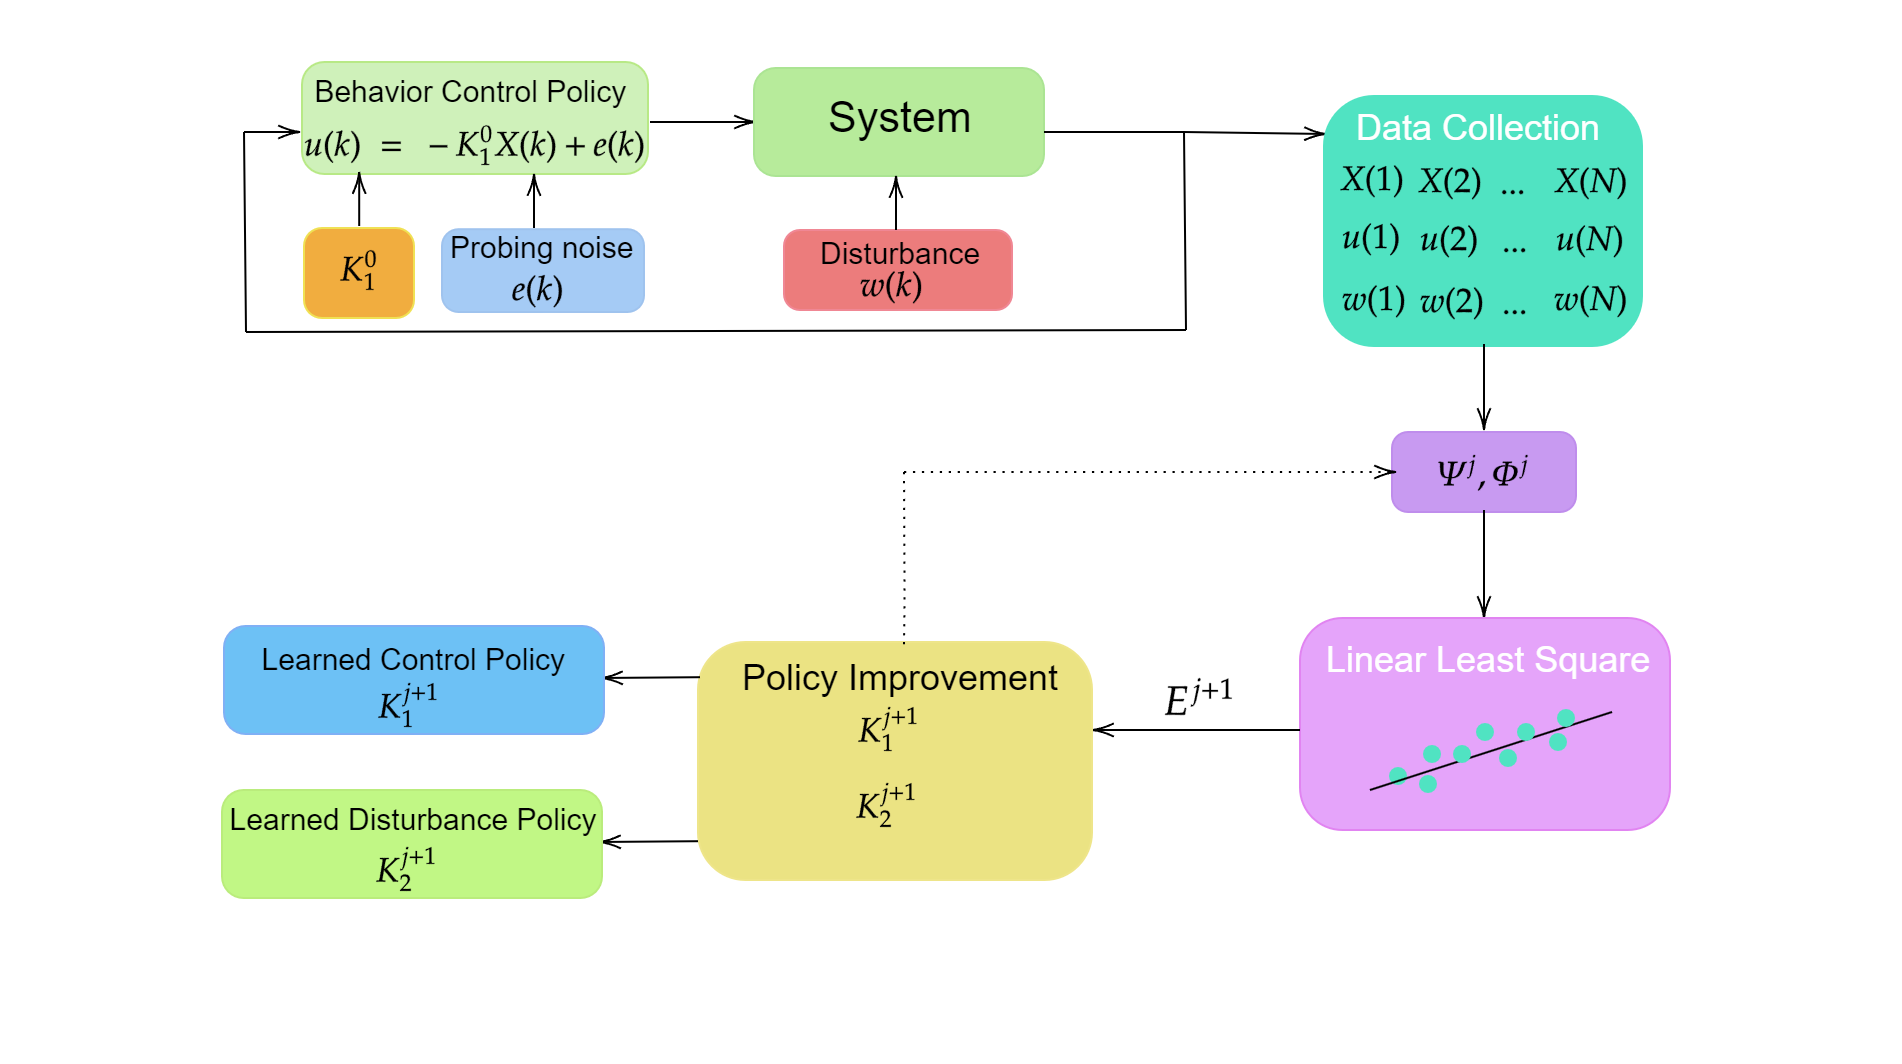
I studied Control Engineering and Automation at Hanoi University of Science and Technology, and before VinMotion I was a research scientist in the Advanced Control and Robotics group with Prof. Phuong Nam Dao. That work was on reinforcement learning, H∞ games, and optimal tracking.
Systems I work on
- Motion 1. Synchronized stage performance for the public, including the A80 national celebrations.
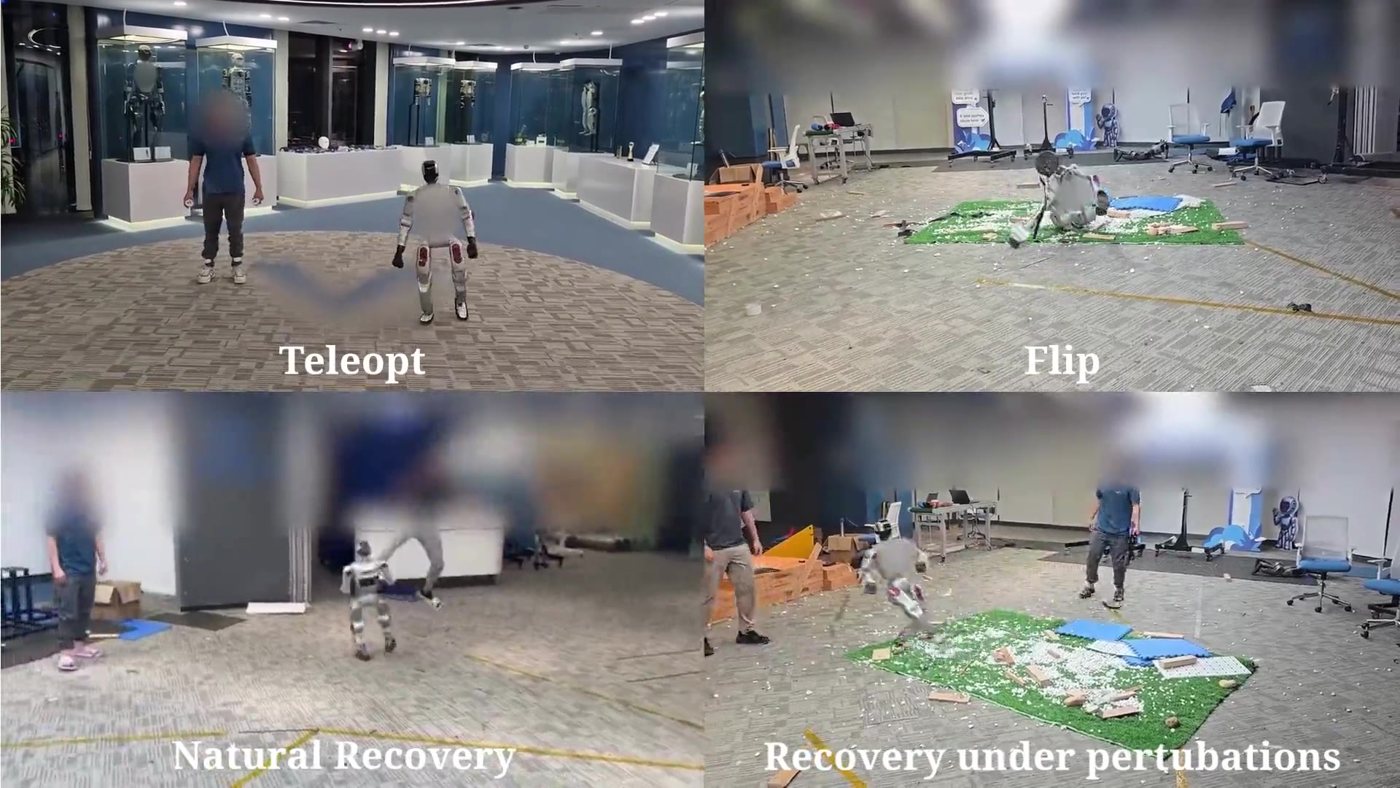
- Motion 2. Global debut at CES 2026 with Qualcomm: walking, boxing, and dancing.
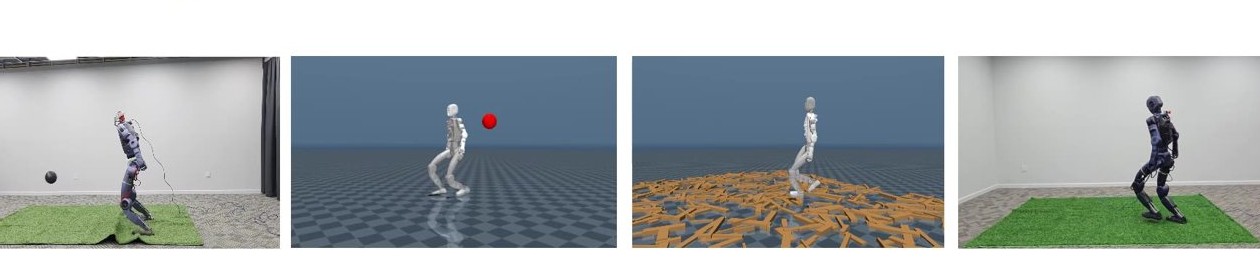
- MiniMotion. A compact humanoid for flips, fall recovery, platform climbing, and balance under a heavy load.
News
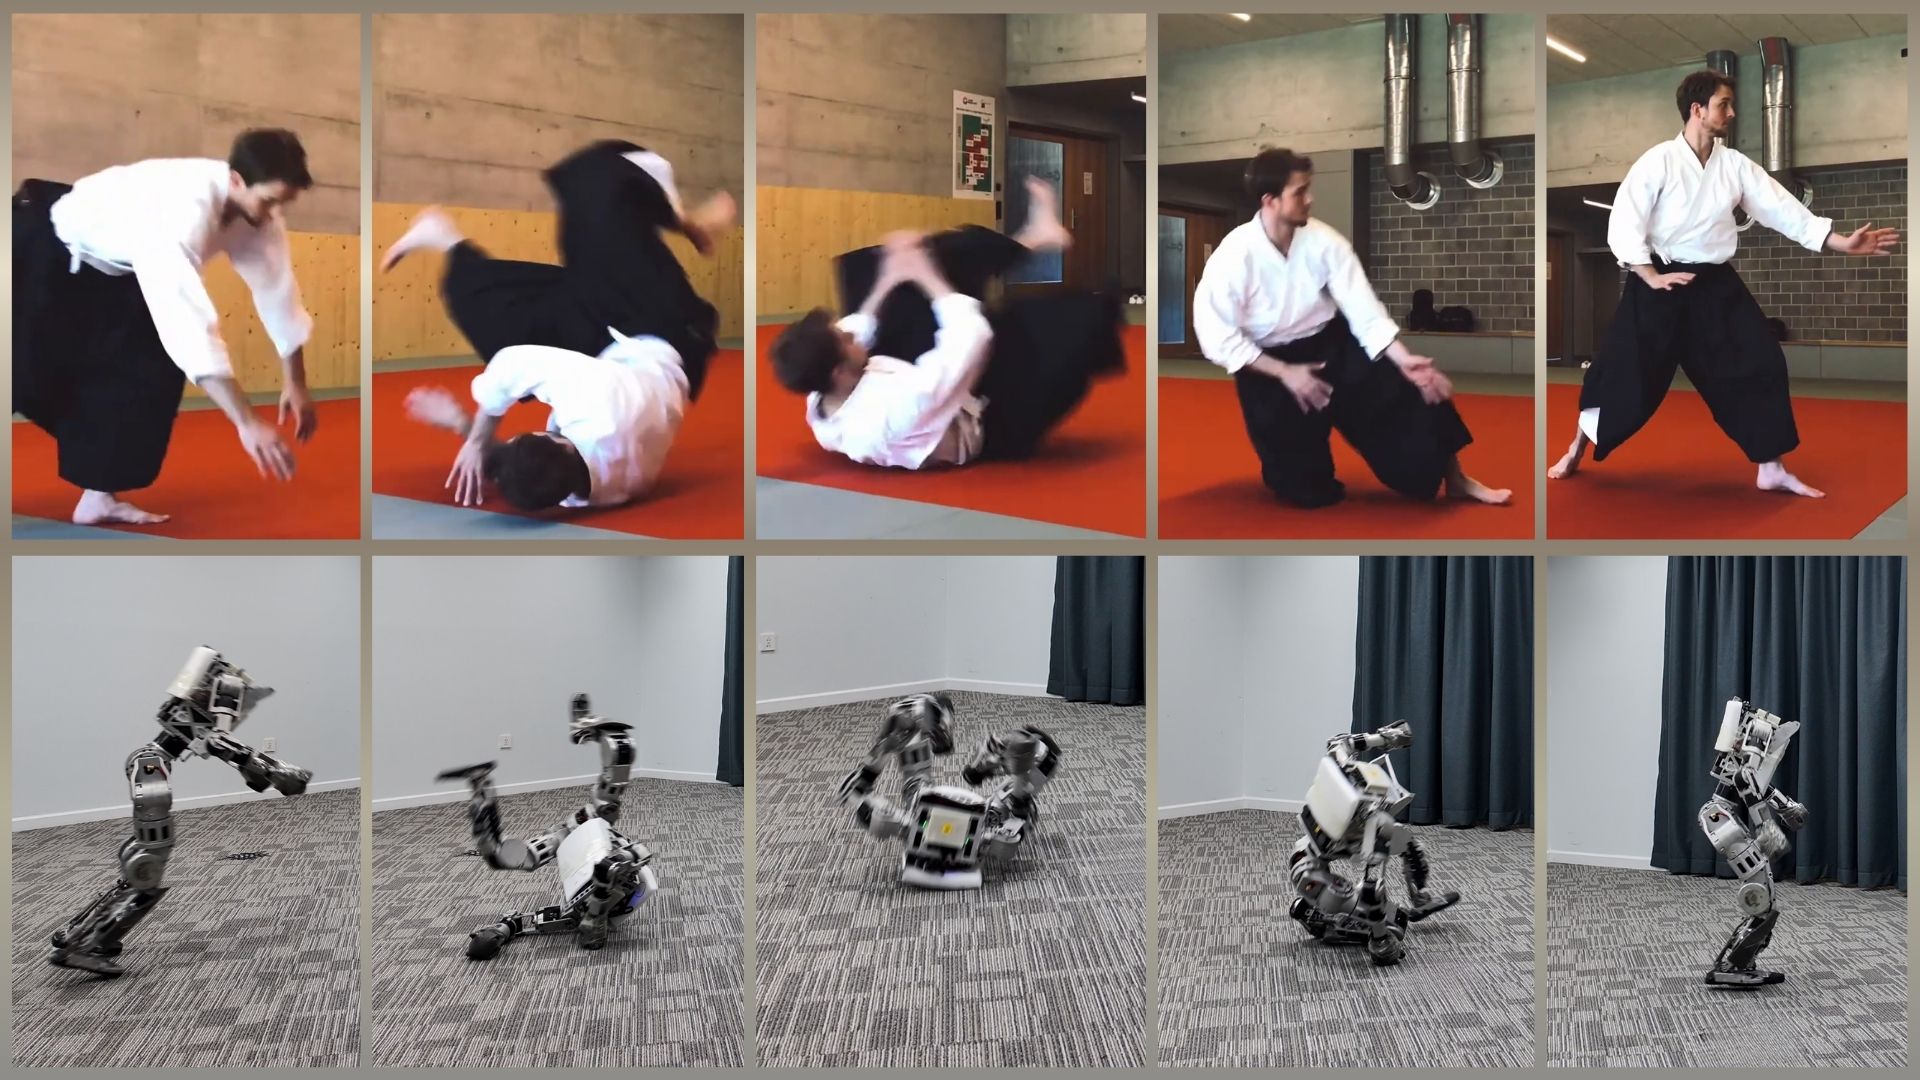
| Oct 08, 2026 | Two papers were accepted at Humanoids: aggressive standing-up across diverse terrains and Ukemi-SafeFall. |
|---|---|
| Oct 01, 2026 | Robotics Engineer at VinMotion Inc. (US). |
| Oct 01, 2026 | X-BFM is under review at ICRA. |
| Aug 20, 2026 | MiniMotion went on stage at Vingroup’s 33rd anniversary: flips, fall recovery, and balance under load. |
| Jan 07, 2026 | Motion 2 debuted at CES 2026 in Las Vegas, with live walking, boxing, and dancing. |
| Aug 19, 2025 | Motion 1 performed for the public at the A80 national celebrations in Hanoi, after a synchronized dance at Vingroup’s 32nd anniversary. |
| Aug 01, 2025 | Graduated from the Talented Engineer Program in Control Engineering and Automation at Hanoi University of Science and Technology (HUST). |
| Apr 01, 2025 | Joined VinMotion as a Robotics Engineer. |
| Mar 01, 2025 | Paper accepted at Chaos, Solitons & Fractals (Q1). |
Awards
- Employee of the Year, VinMotion, 2025.
- Second prize, Vietnam Mathematical Olympiad for Students, Vietnam Mathematical Society, 2022. Certificate.